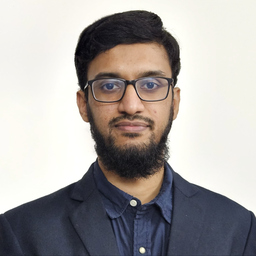
Syed Ibrahim Shakir
Skills
Timeline
Professional experience for Syed Ibrahim Shakir
- 2 years and 2 months, Nov 2022 - Dec 2024
Machine Learning Research Assistant
Fraunhofer-Institut für Intelligente Analyse- und Informationssysteme IAIS
- Distilled vision foundation models for knowledge transfer and model compression, boosting student classification accuracy by 21% - Implemented and evaluated face detection models (RetinaNet, CenterNet, etc) for downstream news media analysis, improving performance by 10-30% across tasks - Explored federated learning as an alternate paradigm for decentralized training in privacy-sensitive applications - Tools: PyTorch, Lightning, Python, Kubernetes, Docker, MLOps, Pandas & Jupyter
- 1 year, Nov 2021 - Oct 2022Fraunhofer-Institut für Intelligente Analyse- und Informationssysteme IAIS
Computer Vision Research Assistant
- Conducted thorough study & evaluation of state-of-the-art object tracking algorithms (e.g., Deep SORT, SiamMask) against real-world data (TAO dataset), identifying model-specific performance limitations in diverse real-world scenarios - Implemented and benchmarked multiple object tracking algorithms, analyzing performance in detection, localization & association using HOTA metrics (achieved 13.3 cumulative score improvement) - Tools: Python, PyTorch, OpenCV, Pandas, NumPy, sklearn, & Jupyter
- 1 year and 4 months, Mar 2019 - Jun 2020
Co-Founder
Robiotics Labs
• Extended bachelor’s thesis work on RAES (Rehabiliation Assistance Exo-Skeleton) • Designed an EMG sensor using FET-based differential amplifier & bandpass filtering • Provided IoT solutions for smart home automation • Tools: Python, Embedded C/C++, OpenCV, Arduino & Raspberry Pi
- 1 year and 4 months, Mar 2018 - Jun 2019
Lead Researcher – Intelligent Robotics
Team Robocon MJCET
• Applied computer vision techniques for stereo depth estimation and real-time object localization in robot navigation • Analyzed human & animal gait patterns to balance robots with shifting center of gravity • Designed a control system for synchronous joint actuation of quadruped robot • Tools: Python, Embedded C/C++, Rotary encoders, IMUs, OpenCV & Stereo Vision
- 1 year and 7 months, Aug 2016 - Feb 2018
Researcher – Robotics & Embedded Systems
Team Robocon MJCET
• Used real-time computer vision (OpenCV) to verify ball throws through target hoops on a Raspberry Pi 3, achieving sub-250ms latency per frame • Built a vision-based color recognition pipeline, replacing legacy laser sensors to trigger robotic task state-machines during the match sequence • Programmed a line-following robot using a PD control loop, reducing deviation from track & enhancing stability in motion of the autonomous robot • Tools: Arduino, ATmega, Raspberry Pi, Embedded C/C++, Python, Matlab
Educational background for Syed Ibrahim Shakir
- 4 years and 3 months, Sep 2020 - Nov 2024
M.Sc. Autonomous Systems
Hochschule Bonn-Rhein-Sieg
Thesis: Efficacy of Foundation-Model-Based Distillation for Image Classification
- 3 years and 11 months, Aug 2015 - Jun 2019
B.Eng. Electronics and Communications
Osmania University
Rehabilitation Assistance Exo-Skeleton
Languages
English
C1 (Fluent)
German
B1-B2 (Good)
Urdu
C2 (Expert / native speaker)
Hind
B1-B2 (Good)
XING members with similar profiles
XING – The jobs network
Over 1 million jobs
Find just the right job for you on XING.
Job offers just for you
Get found by employers and over 20,000 recruiters.
21 million members
Connect with new people and gather inspiration to boost your working life.
Free membership
Basic membership is free, but the opportunities are priceless.